Rocket Booster Attitude Control
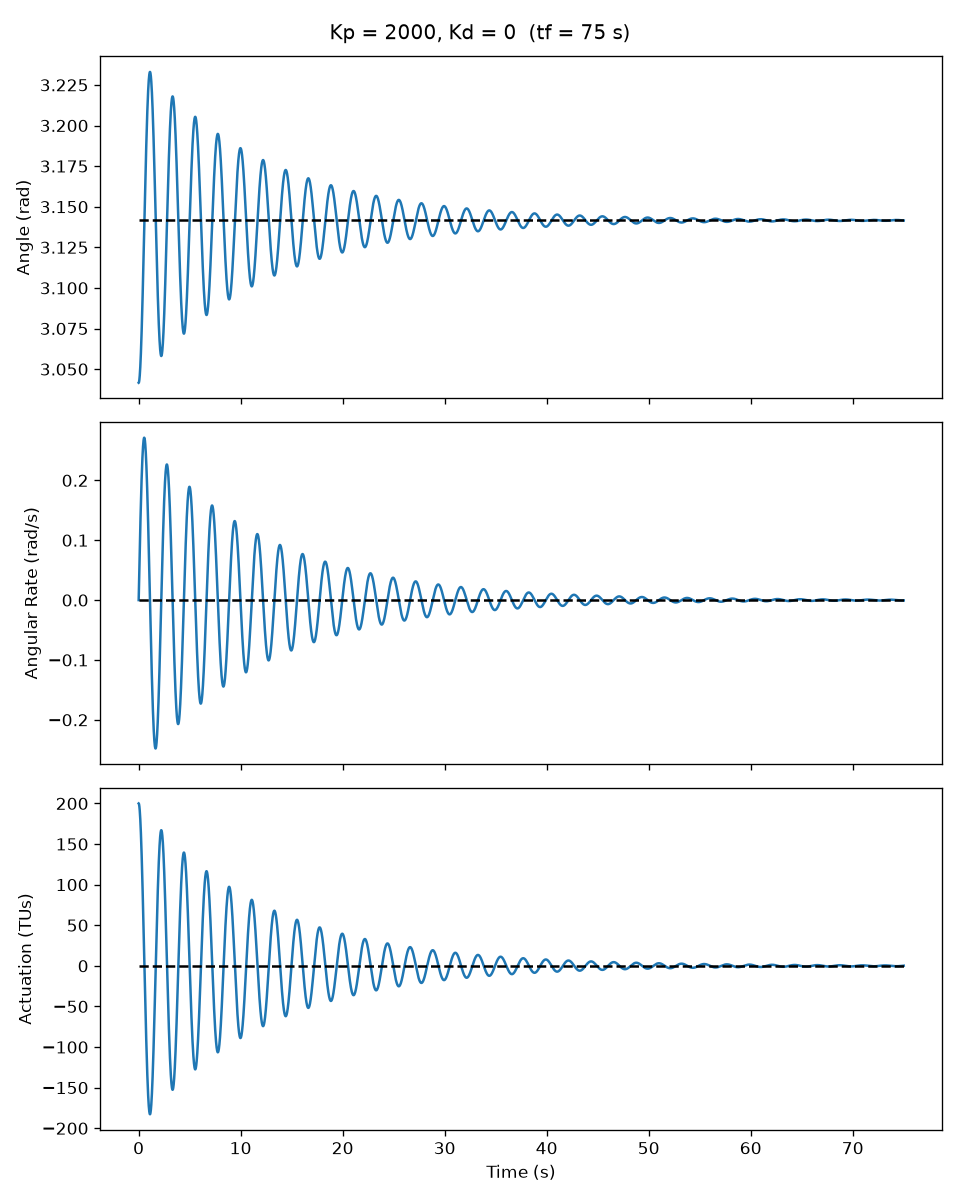
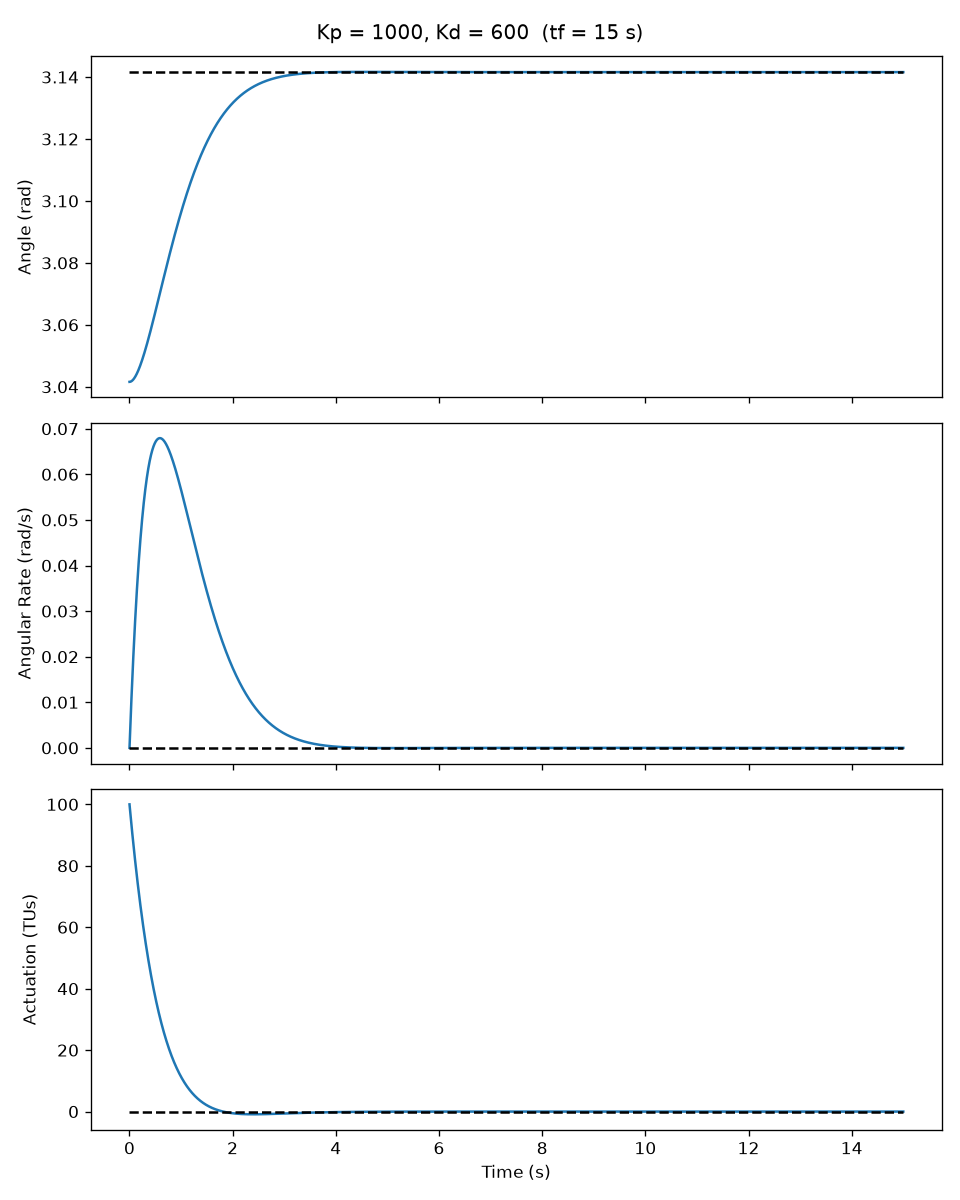
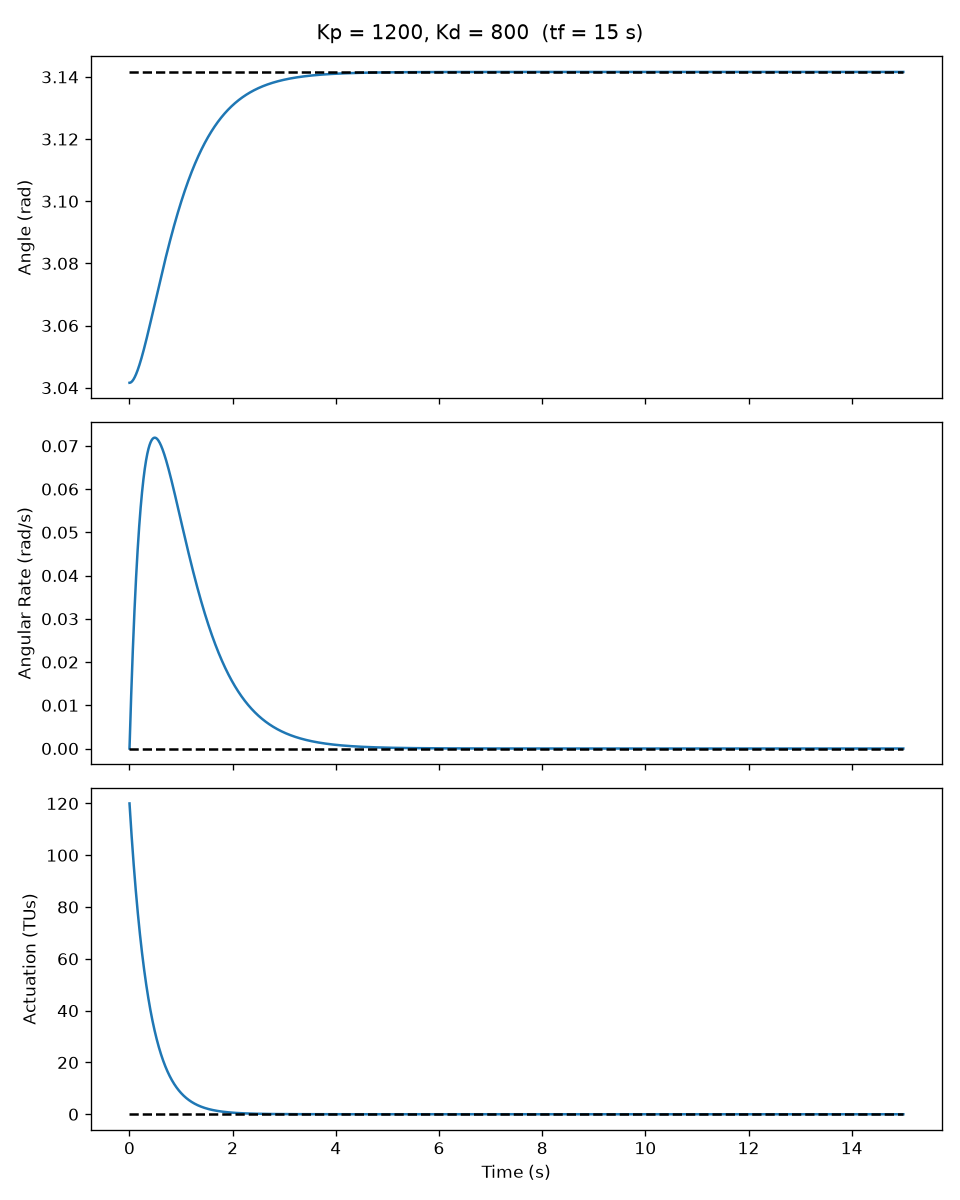
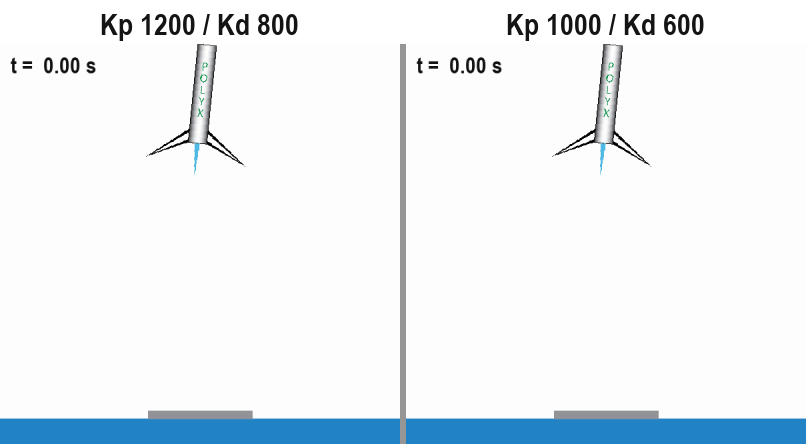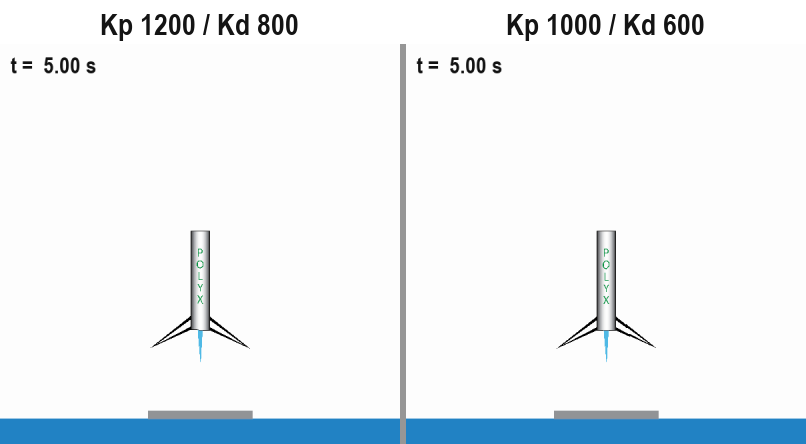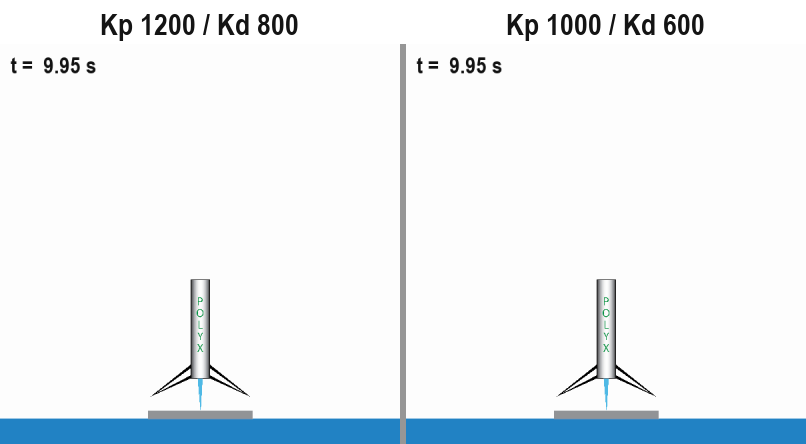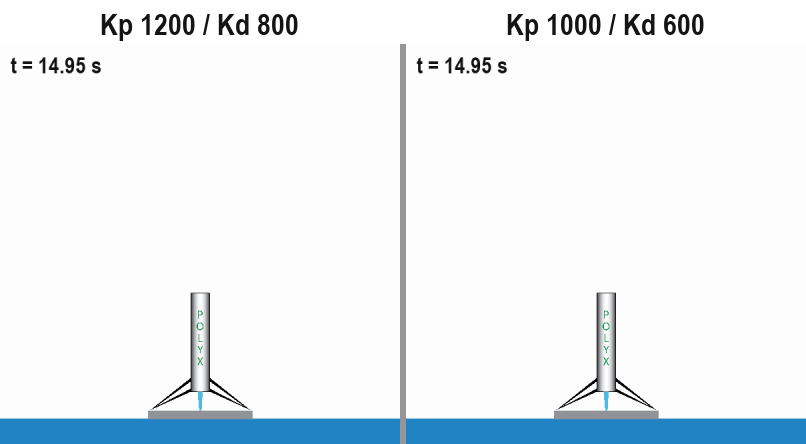
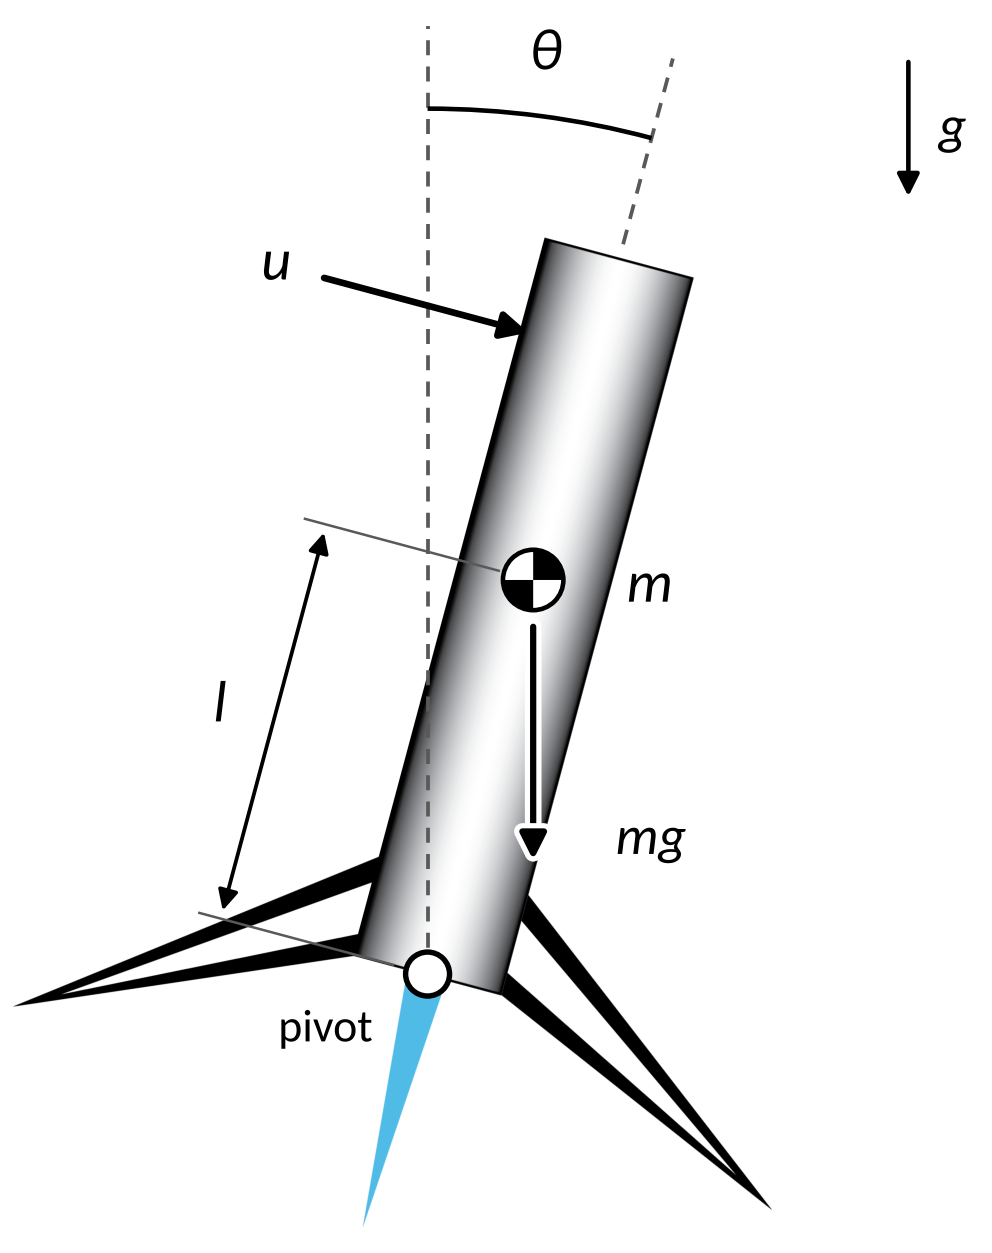
Tuned a PD controller (Kp = 1200, Kd = 800) that returns a landing booster to vertical in 3.15 s with no overshoot. Requirement: recover from a 5.7° tilt with at most 1% overshoot, settling in under 5 s. The booster is modeled as an inverted pendulum, 16.4 ft long and 441 lb. Proportional gain alone raised overshoot (66% at Kp = 500, 92% at Kp = 2000), so I added derivative damping. I chose Kp = 1200, Kd = 800 over Kp = 1000, Kd = 600 because it gives up 0.35 s of settling time to remove the 0.1% overshoot, which matters on a landing.
Simulated only: course Python model, no disturbances.
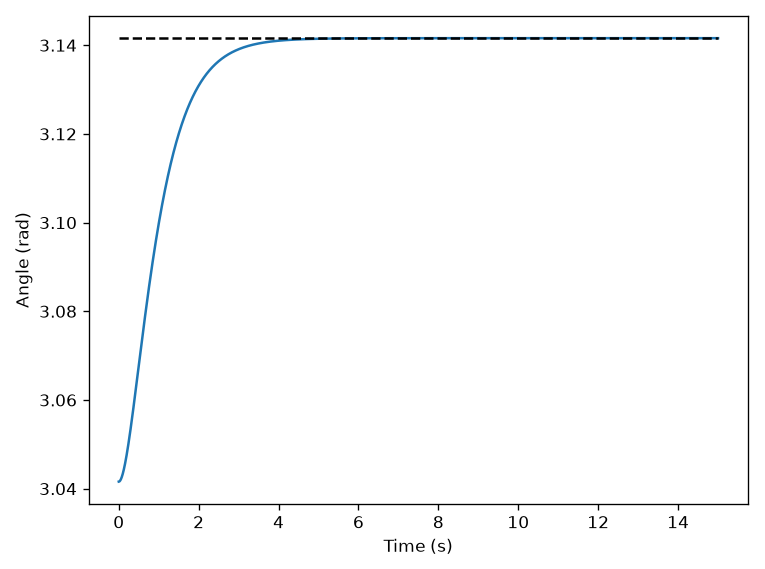
Controller tuning